A drone learning to fly
A modular Gymnasium environment for quadrotor hover, waypoint tracking, obstacle navigation, and depth-camera perception.
Agent replay
Recorded agents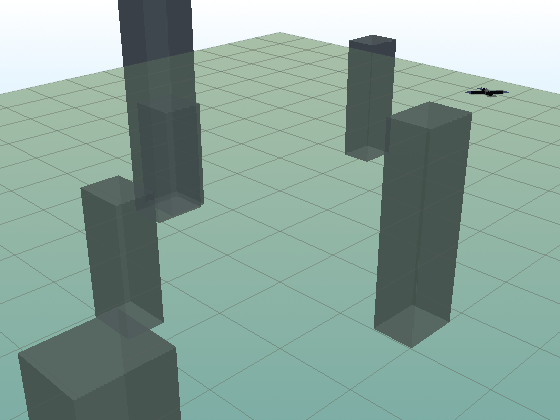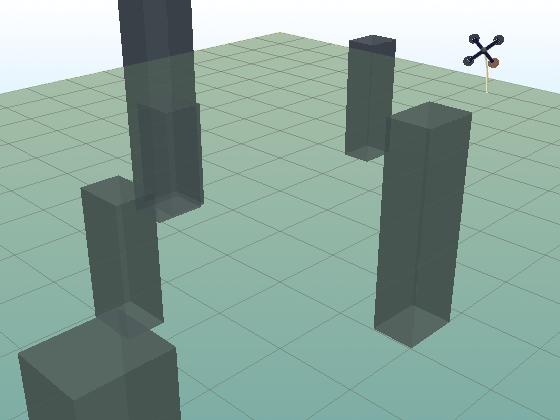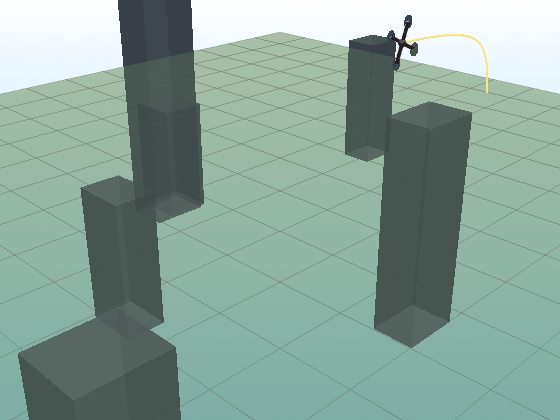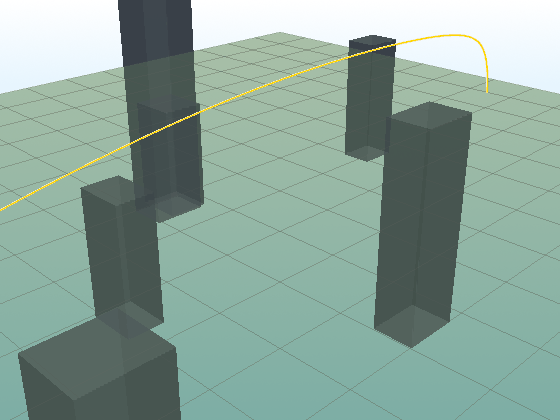

How it works.
Choose the task
Configure hover, waypoints, trajectory tracking, or navigation with point-mass or six-degree-of-freedom physics.
From the original project.
Saved artifacts · click to inspect
Original artifact ↗
Original artifact ↗

Original artifact ↗

Continue in the source.
Follow the source README for the original runtime, dependencies, data, and configuration.
git clone https://github.com/eforus-overseer/rotorenv.gitProject artifacts.
examples/curriculum_demo.py ↗examples/random_agent.py ↗examples/render_6dof.py ↗examples/render_flight.py ↗examples/train_nav_curriculum.py ↗examples/train_ppo.py ↗
Source links point to the original public repository. Credit belongs to the project authors and the dependencies credited there.